Research & Development
Records of our research and development
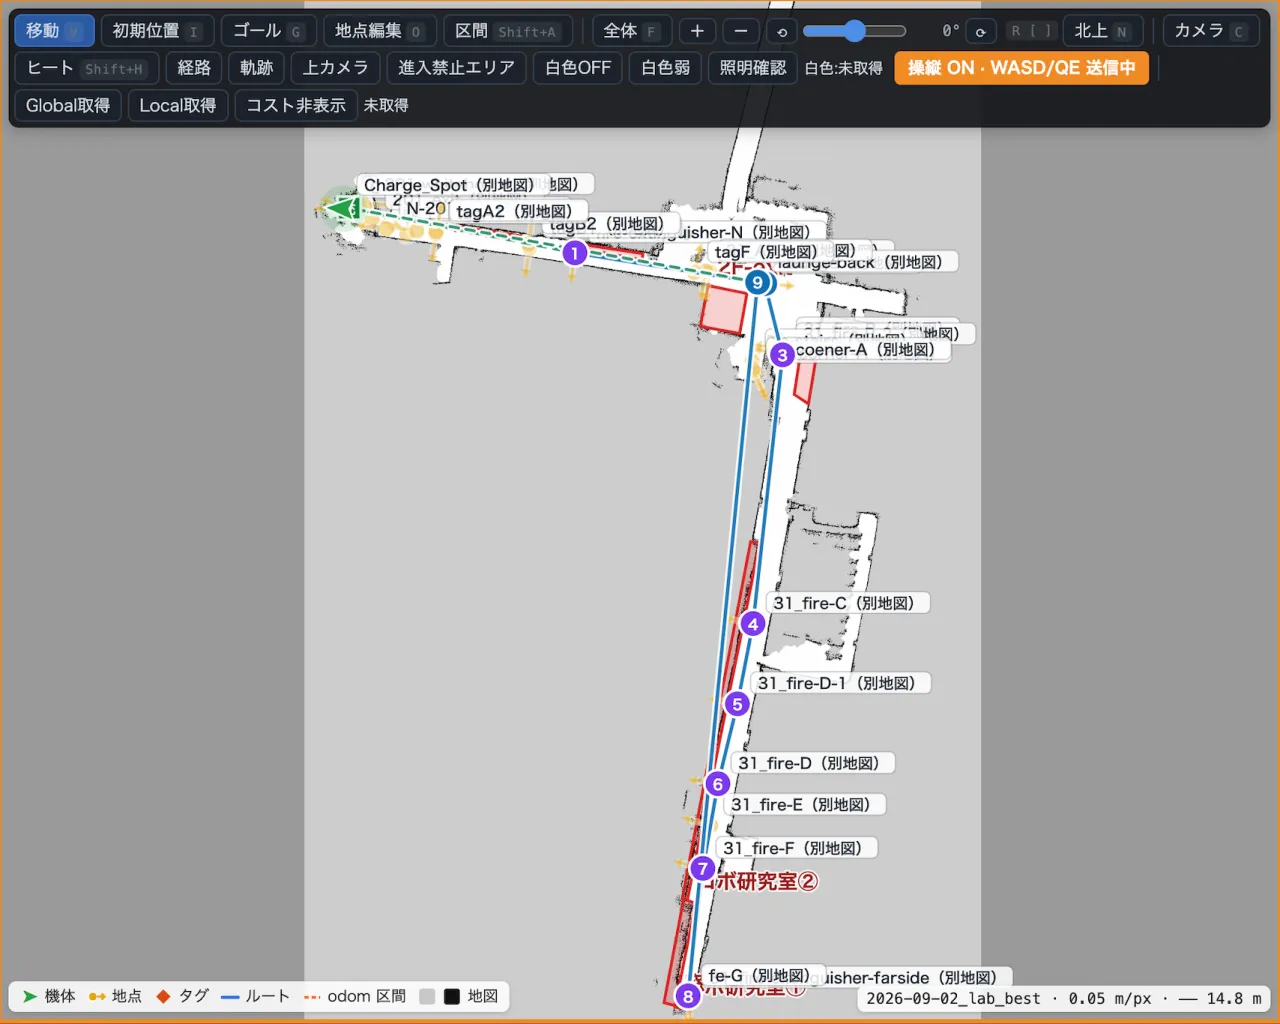
The LiDAR built into Unitree Go2 could not produce an accurate map on its own. Our own system solved this, achieving point-cloud mapping and navigation over a 100 m × 100 m area without additional hardware.
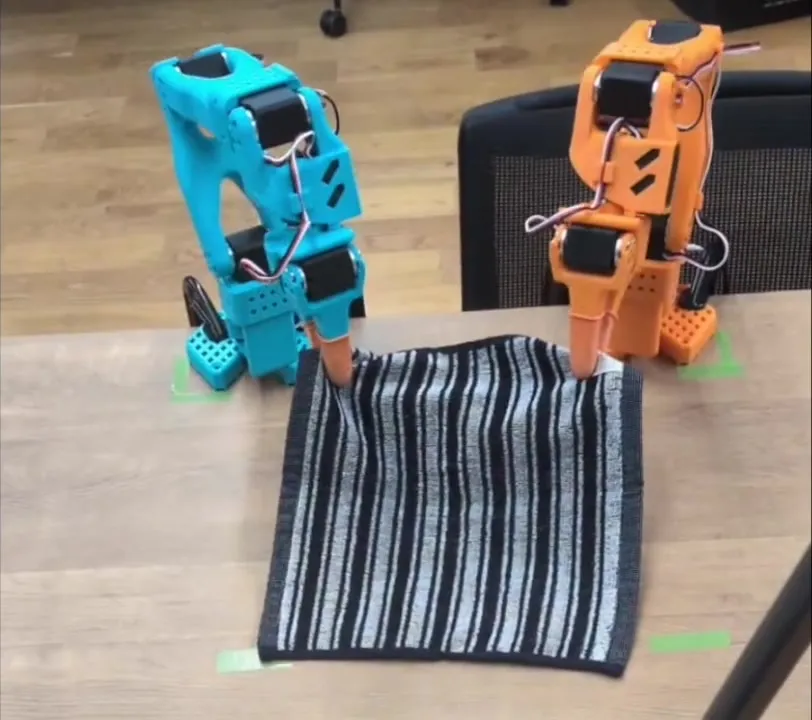
Trained on 100 demonstrations, ACT folded a handkerchief into quarters in 37 of 40 trials under the same cloth and placement conditions. Failures with different patterns or positions show the limits we are investigating on the real robot.
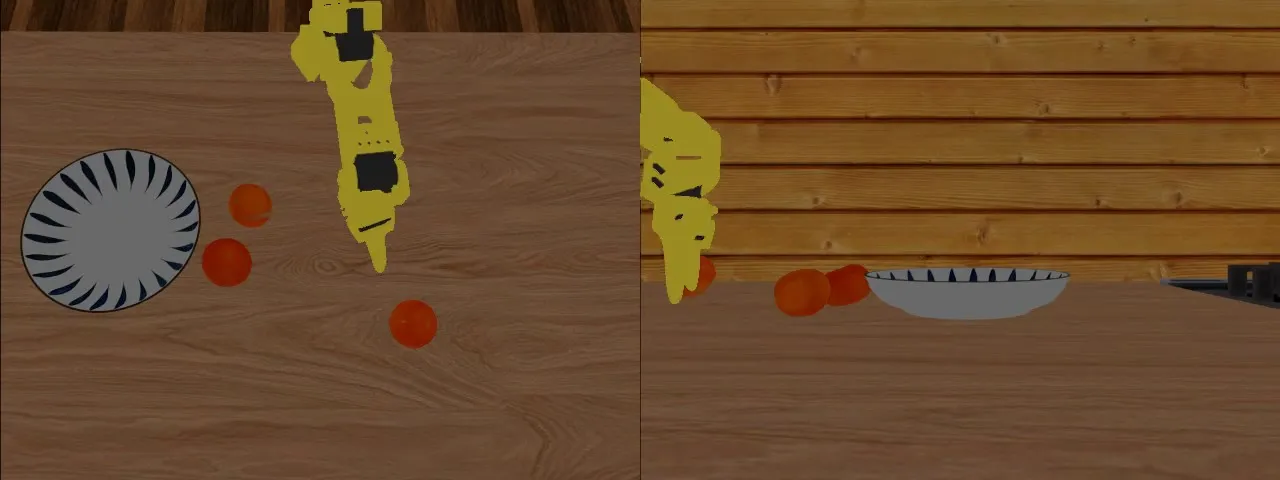
An experiment teaching a robot to move oranges onto a plate revealed that its success metric measured proximity instead. Human video review led to revised success criteria, rewards, and AI audit questions. Here is what was verified and what remains unresolved.
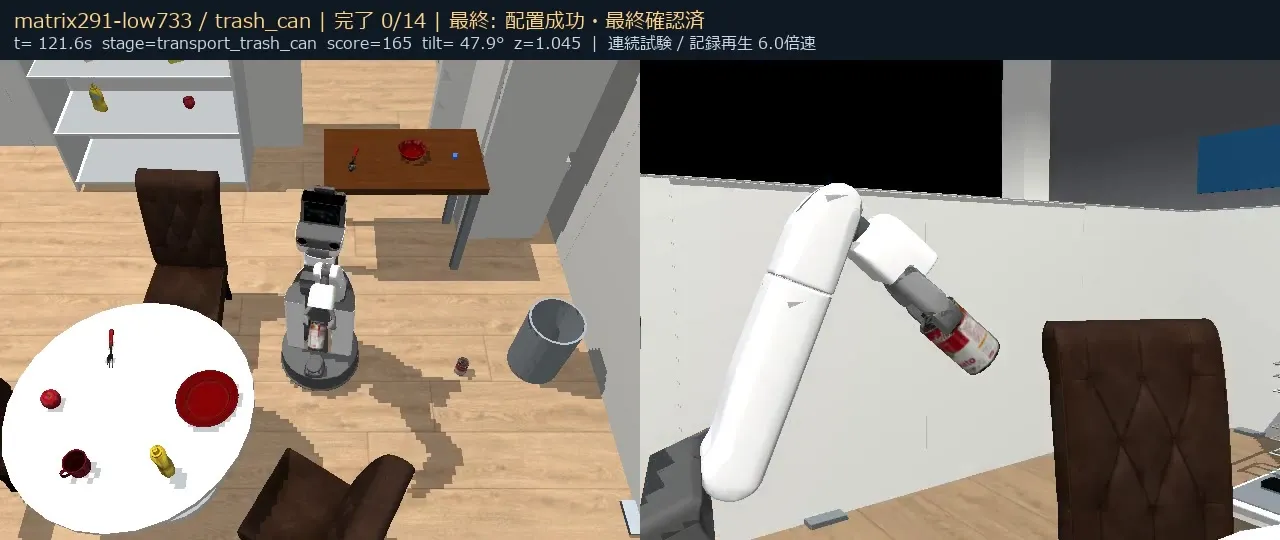
Using household tasks from RoboCup, we grasp, carry, and place objects with rule-based control, and use an LLM to update those rules based on test results in simulation.